
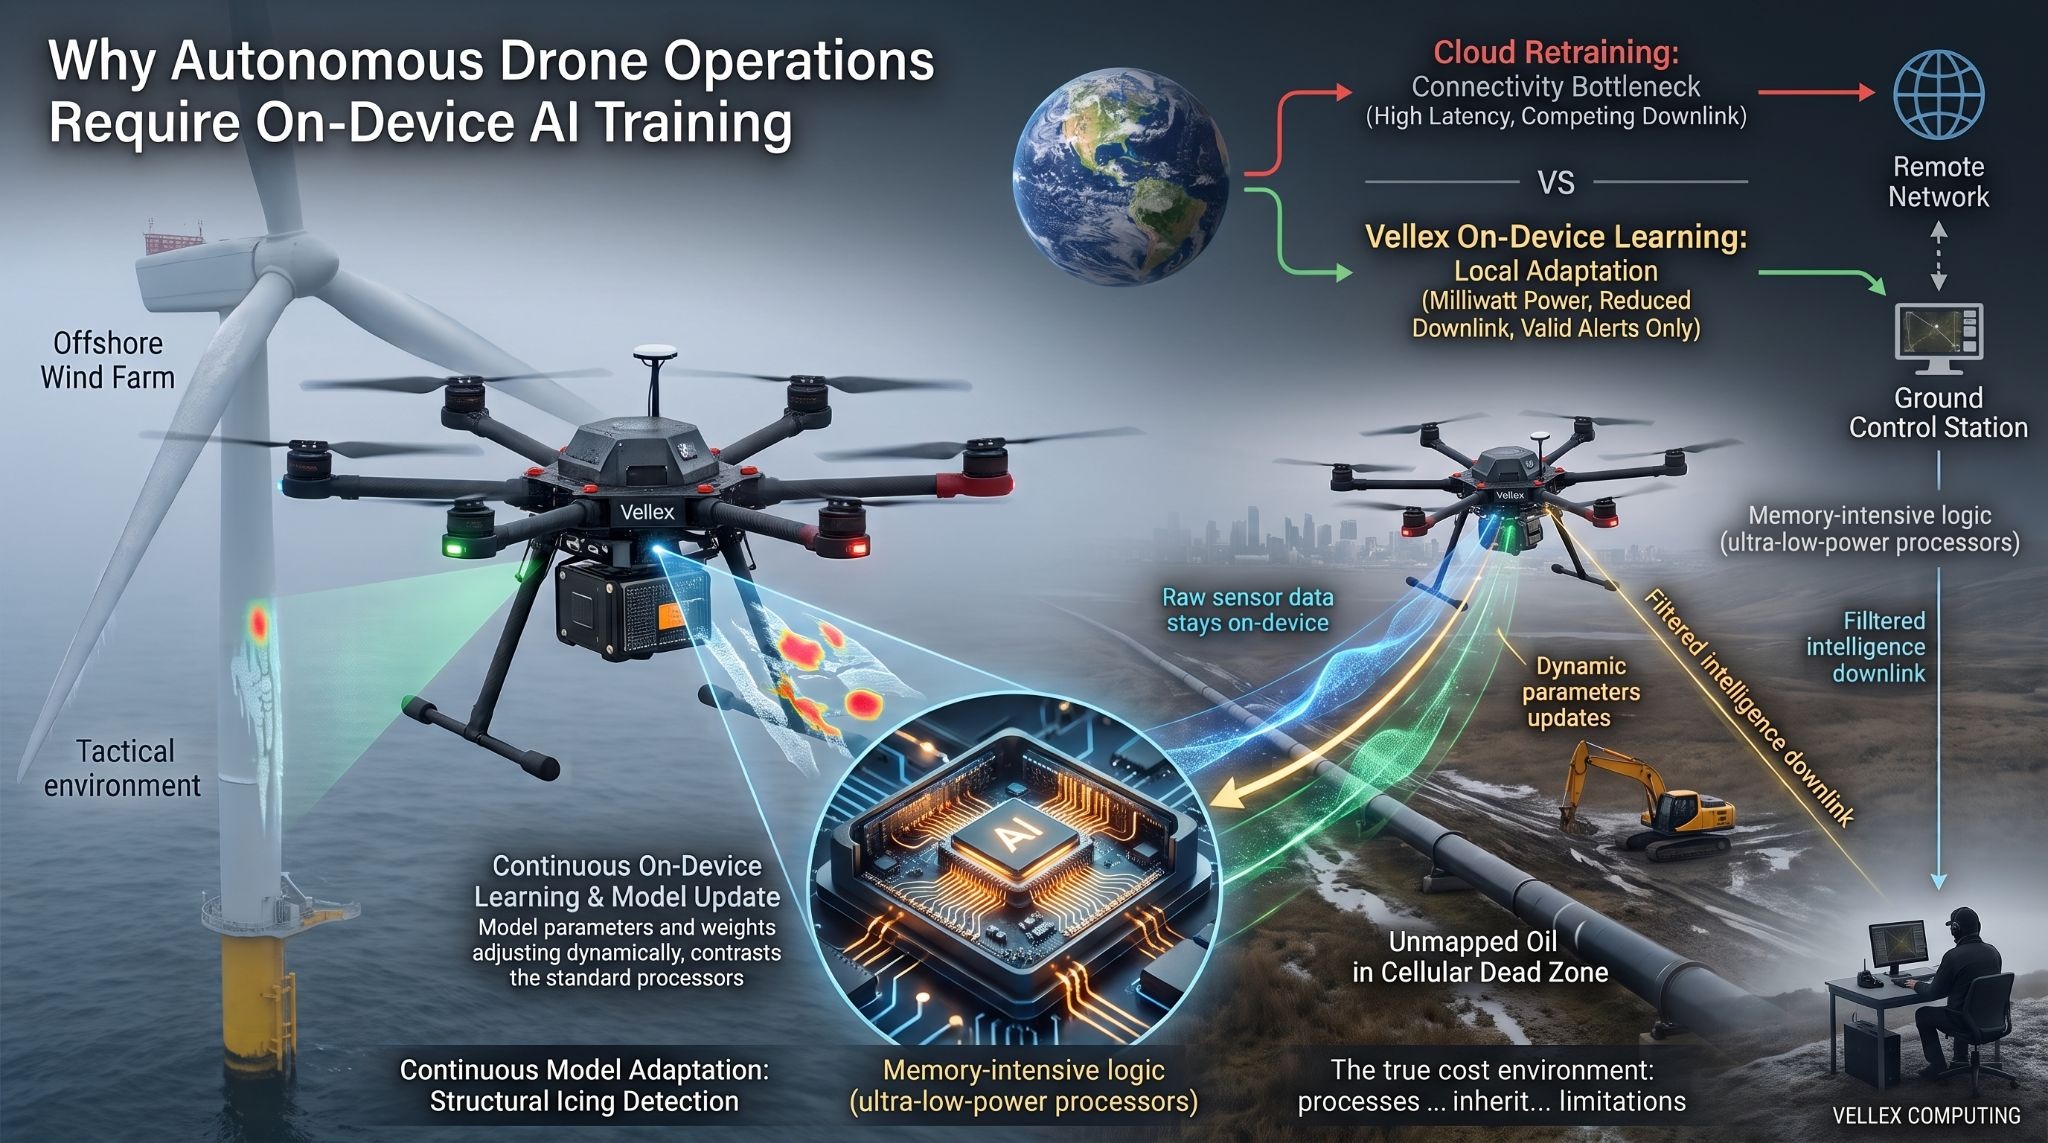
Autonomous drones provide critical oversight for industrial infrastructure like pipelines, offshore wind farms, and tactical reconnaissance in contested environments. To process visual data autonomously, these systems run AI inference locally, using pre-trained, fixed-weight models to identify anomalies before transmitting data to the ground.
When the drone encounters conditions absent from its training data, static models fail. This could be a novel pattern of structural icing on a wind turbine, unmapped construction equipment near a pipeline, or an unrecognized adversary vehicle signature. When live data diverges from the dataset used to train the original model, the anomaly goes undetected. Restoring accuracy requires updating the neural network parameters, and current computing architectures force that process off-device.
To fix model drift, operators rely on a ground-based retraining loop. The drone transmits raw mission data to a remote server, engineering teams retrain the model in the cloud, and the updated parameters are downloaded back to the deployed hardware.
This cloud dependency is operationally fragile. Modern drone payloads equipped with optical cameras, multispectral sensors, and LiDAR arrays generate high volumes of raw data per flight. Critical infrastructure is frequently located in cellular dead zones, while tactical deployments actively face electronic warfare and signal jamming. Streaming gigabytes of footage over an intermittent rural LTE connection or a heavily contested network is unviable. Every megabyte of raw training data sent consumes bandwidth required for actionable intelligence.
Latency compounds this bottleneck. The round-trip from a viable connection to uploaded data to cloud retraining to the downloaded model takes hours or days. During this window, the drone operates with degraded analytical capabilities. By the time the updated model reaches the hardware, the environmental hazard or tactical situation has likely escalated, making time-sensitive intelligence unreliable.
Running the training process directly on the drone eliminates the connectivity bottleneck. The physical barrier is payload power.
Standard digital processors execute AI training through continuous data movement between memory and compute cores, calculating gradients over millions of discrete clock cycles. This architecture draws tens of watts for training workloads.
In an autonomous drone, battery power is a zero-sum resource. Every watt consumed by the payload processor is a watt stolen from the propulsion system. Allocating that budget to a digital training workload drains the flight battery, forcing the drone to terminate its mission prematurely. This power constraint is what keeps AI training off-device.
Operating on-device eliminates the data transmission requirement for model updates. Raw sensor data stays on the drone. A system equipped to train locally discards environmental noise and uses its limited radio bandwidth exclusively for high-value alerts. Onboard models update autonomously to recognize new physical realities, whether structural damage or novel camouflage, without waiting for a stable network connection and without depending on remote infrastructure.
The true cost of the ground-based retraining loop is the operational dependency it creates. Every remote aerial system that relies on data center retraining inherits the connectivity, latency, and data pipeline limitations of that architecture.
Vellex builds analog compute hardware that runs AI training directly on-device. The approach maps optimization mathematics onto analog circuits, which settle to a solution through circuit dynamics rather than iterating through millions of discrete digital steps. The result is AI training at milliwatt power levels, compatible with the strict power budgets of battery-operated payloads.
By keeping training on the drone, Vellex-equipped systems maintain model accuracy autonomously as conditions change, without draining the flight battery to run digital compute or relying on vulnerable remote networks to push updates.
READ MORE


